#include <velocityprofile_traphalf.hpp>
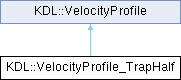
A 'Half' Trapezoidal VelocityProfile. A constructor flag indicates if the calculated profile should be starting or ending.
◆ VelocityProfile_TrapHalf()
| KDL::VelocityProfile_TrapHalf::VelocityProfile_TrapHalf |
( |
double | _maxvel = 0, |
|
|
double | _maxacc = 0, |
|
|
bool | _starting = true ) |
- Parameters
-
| maxvel | maximal velocity of the motion profile (positive) |
| maxacc | maximal acceleration of the motion profile (positive) |
| starting | this value is true when initial velocity is zero and ending velocity is maxvel, is false for the reverse |
◆ ~VelocityProfile_TrapHalf()
| virtual KDL::VelocityProfile_TrapHalf::~VelocityProfile_TrapHalf |
( |
| ) |
|
|
virtual |
◆ Acc()
| virtual double KDL::VelocityProfile_TrapHalf::Acc |
( |
double | time | ) |
const |
|
virtual |
◆ Clone()
◆ Duration()
| virtual double KDL::VelocityProfile_TrapHalf::Duration |
( |
| ) |
const |
|
virtual |
◆ Pos()
| virtual double KDL::VelocityProfile_TrapHalf::Pos |
( |
double | time | ) |
const |
|
virtual |
◆ SetMax()
| void KDL::VelocityProfile_TrapHalf::SetMax |
( |
double | _maxvel, |
|
|
double | _maxacc, |
|
|
bool | _starting ) |
◆ SetProfile()
| virtual void KDL::VelocityProfile_TrapHalf::SetProfile |
( |
double | pos1, |
|
|
double | pos2 ) |
|
virtual |
◆ SetProfileDuration()
| virtual void KDL::VelocityProfile_TrapHalf::SetProfileDuration |
( |
double | pos1, |
|
|
double | pos2, |
|
|
double | newduration ) |
|
virtual |
Can be used to prolong the profile, there are two possible outcomes: in a first phase the acceleration is lowered as such that the end position and maximum velocity are reached at the given duration (newduration). In this case there is an acceleration part and a constant velocity part, when this reaches a minimum acceleration value at which the constant part disappears, the motion is stalled, in this case their is a non-motion part and an acceleration part.
- Parameters
-
| pos1 | starting position |
| pos2 | ending position |
| newduration | the desired duration, if it is lower than the minimum duration, the minimum duration will be used instead of the given duration. |
Implements KDL::VelocityProfile.
◆ Vel()
| virtual double KDL::VelocityProfile_TrapHalf::Vel |
( |
double | time | ) |
const |
|
virtual |
◆ Write()
| virtual void KDL::VelocityProfile_TrapHalf::Write |
( |
std::ostream & | os | ) |
const |
|
virtual |
The documentation for this class was generated from the following file:
 1.16.1