#include <rotational_interpolation_sa.hpp>
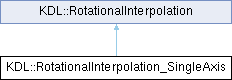
Public Member Functions | |
| RotationalInterpolation_SingleAxis () | |
| virtual void | SetStartEnd (Rotation start, Rotation end) |
| virtual double | Angle () |
| virtual Rotation | Pos (double th) const |
| virtual Vector | Vel (double th, double thd) const |
| virtual Vector | Acc (double th, double thd, double thdd) const |
| virtual void | Write (std::ostream &os) const |
| virtual RotationalInterpolation * | Clone () const |
| virtual | ~RotationalInterpolation_SingleAxis () |
| Public Member Functions inherited from KDL::RotationalInterpolation | |
| virtual | ~RotationalInterpolation () |
Additional Inherited Members | |
| Static Public Member Functions inherited from KDL::RotationalInterpolation | |
| static RotationalInterpolation * | Read (std::istream &is) |
Detailed Description
An interpolation algorithm which rotates a frame over the existing single rotation axis formed by start and end rotation. If more than one rotational axis exist, an arbitrary one will be chosen, therefore it is not recommended to try to interpolate a 180 degrees rotation.
Constructor & Destructor Documentation
◆ RotationalInterpolation_SingleAxis()
| KDL::RotationalInterpolation_SingleAxis::RotationalInterpolation_SingleAxis | ( | ) |
◆ ~RotationalInterpolation_SingleAxis()
|
virtual |
Member Function Documentation
◆ Acc()
|
virtual |
Returns the rotational acceleration at angle theta and with derivative of theta == thetad, and 2nd derivative of theta == thdd
Implements KDL::RotationalInterpolation.
◆ Angle()
|
virtual |
- Returns the angle value to move from start to end. This should have units radians,
- With Single Axis interp corresponds to the angle rotation
- With Three Axis interp corresponds to the slowest of the three rotations.
Implements KDL::RotationalInterpolation.
◆ Clone()
|
virtual |
virtual constructor, construction by copying ..
Implements KDL::RotationalInterpolation.
◆ Pos()
|
virtual |
Returns the rotation matrix at angle theta
Implements KDL::RotationalInterpolation.
◆ SetStartEnd()
|
virtual |
Set the start and end rotational_interpolation
Implements KDL::RotationalInterpolation.
◆ Vel()
|
virtual |
Returns the rotational velocity at angle theta and with derivative of theta == thetad
Implements KDL::RotationalInterpolation.
◆ Write()
|
virtual |
Writes one of the derived objects to the stream
Implements KDL::RotationalInterpolation.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/rotational_interpolation_sa.hpp
Generated by
 1.16.1