#include <rotational_interpolation.hpp>
Public Member Functions | |
| virtual void | SetStartEnd (Rotation start, Rotation end)=0 |
| virtual double | Angle ()=0 |
| virtual Rotation | Pos (double theta) const =0 |
| virtual Vector | Vel (double theta, double thetad) const =0 |
| virtual Vector | Acc (double theta, double thetad, double thetadd) const =0 |
| virtual void | Write (std::ostream &os) const =0 |
| virtual RotationalInterpolation * | Clone () const =0 |
| virtual | ~RotationalInterpolation () |
Static Public Member Functions | |
| static RotationalInterpolation * | Read (std::istream &is) |
Detailed Description
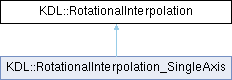
RotationalInterpolation specifies the rotational part of a geometric trajectory
- The different derived objects specify different methods for interpolating rotations.
- SetStartEnd should be called before using the other methods
- The start and end position do NOT belong to the persistent state ! The owner of this object is responsible for setting these each time
Constructor & Destructor Documentation
◆ ~RotationalInterpolation()
|
inlinevirtual |
Member Function Documentation
◆ Acc()
|
pure virtual |
Returns the rotational acceleration at angle theta and with derivative of theta == thetad, and 2nd derivative of theta == thdd
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Angle()
|
pure virtual |
- Returns the angle value to move from start to end. This should have units radians,
- With Single Axis interp corresponds to the angle rotation
- With Three Axis interp corresponds to the slowest of the three rotations.
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Clone()
|
pure virtual |
virtual constructor, construction by copying ..
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Pos()
|
pure virtual |
Returns the rotation matrix at angle theta
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Read()
|
static |
Reads one of the derived objects from the stream and returns a pointer (factory method)
◆ SetStartEnd()
|
pure virtual |
Set the start and end rotational_interpolation
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Vel()
|
pure virtual |
Returns the rotational velocity at angle theta and with derivative of theta == thetad
Implemented in KDL::RotationalInterpolation_SingleAxis.
◆ Write()
|
pure virtual |
Writes one of the derived objects to the stream
Implemented in KDL::RotationalInterpolation_SingleAxis.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/rotational_interpolation.hpp
Generated by
 1.16.1