#include <treeiksolverpos_online.hpp>
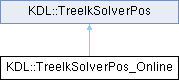
Public Member Functions | |
| TreeIkSolverPos_Online (const double &nr_of_jnts, const std::vector< std::string > &endpoints, const JntArray &q_min, const JntArray &q_max, const JntArray &q_dot_max, const double x_dot_trans_max, const double x_dot_rot_max, TreeFkSolverPos &fksolver, TreeIkSolverVel &iksolver) | |
| ~TreeIkSolverPos_Online () | |
| virtual double | CartToJnt (const JntArray &q_in, const Frames &p_in, JntArray &q_out) |
| Public Member Functions inherited from KDL::TreeIkSolverPos | |
| virtual | ~TreeIkSolverPos () |
Detailed Description
Implementation of a general inverse position kinematics algorithm to calculate the position transformation from Cartesian to joint space of a general KDL::Tree. This class has been derived from the TreeIkSolverPos_NR_JL class, but was modified for online solving for use in realtime systems. Thus, the calculation is only done once, meaning that no iteration is done, because this solver is intended to run at a high frequency. It enforces velocity limits in task as well as in joint space. It also takes joint limits into account.
Constructor & Destructor Documentation
◆ TreeIkSolverPos_Online()
| KDL::TreeIkSolverPos_Online::TreeIkSolverPos_Online | ( | const double & | nr_of_jnts, |
| const std::vector< std::string > & | endpoints, | ||
| const JntArray & | q_min, | ||
| const JntArray & | q_max, | ||
| const JntArray & | q_dot_max, | ||
| const double | x_dot_trans_max, | ||
| const double | x_dot_rot_max, | ||
| TreeFkSolverPos & | fksolver, | ||
| TreeIkSolverVel & | iksolver ) |
Constructor of the solver, it needs the number of joints of the tree, a list of the endpoints you are interested in, the maximum and minimum values you want to enforce and a forward position kinematics solver as well as an inverse velocity kinematics solver for the calculations
- Parameters
-
nr_of_jnts number of joints of the tree to calculate the joint positions for endpoints the list of endpoints you are interested in q_min the minimum joint positions q_max the maximum joint positions q_dot_max the maximum joint velocities x_dot_trans_max the maximum translational velocity of your endpoints x_dot_rot_max the maximum rotational velocity of your endpoints fksolver a forward position kinematics solver iksolver an inverse velocity kinematics solver
- Returns
◆ ~TreeIkSolverPos_Online()
| KDL::TreeIkSolverPos_Online::~TreeIkSolverPos_Online | ( | ) |
Member Function Documentation
◆ CartToJnt()
|
virtual |
Calculate inverse position kinematics, from cartesian coordinates to joint coordinates.
- Parameters
-
q_init initial guess of the joint coordinates p_in input cartesian coordinates q_out output joint coordinates
- Returns
- if < 0 something went wrong otherwise (>=0) remaining (weighted) distance to target
Implements KDL::TreeIkSolverPos.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/treeiksolverpos_online.hpp
Generated by
 1.16.1