KDL::TreeIkSolverPos_NR_JL Class Reference
#include <treeiksolverpos_nr_jl.hpp>
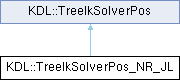
Inheritance diagram for KDL::TreeIkSolverPos_NR_JL:
Public Member Functions | |
| TreeIkSolverPos_NR_JL (const Tree &tree, const std::vector< std::string > &endpoints, const JntArray &q_min, const JntArray &q_max, TreeFkSolverPos &fksolver, TreeIkSolverVel &iksolver, unsigned int maxiter=100, double eps=1e-6) | |
| ~TreeIkSolverPos_NR_JL () | |
| virtual double | CartToJnt (const JntArray &q_init, const Frames &p_in, JntArray &q_out) |
| Public Member Functions inherited from KDL::TreeIkSolverPos | |
| virtual | ~TreeIkSolverPos () |
Detailed Description
Implementation of a general inverse position kinematics algorithm based on Newton-Raphson iterations to calculate the position transformation from Cartesian to joint space of a general KDL::Tree. Takes joint limits into account.
Constructor & Destructor Documentation
◆ TreeIkSolverPos_NR_JL()
| KDL::TreeIkSolverPos_NR_JL::TreeIkSolverPos_NR_JL | ( | const Tree & | tree, |
| const std::vector< std::string > & | endpoints, | ||
| const JntArray & | q_min, | ||
| const JntArray & | q_max, | ||
| TreeFkSolverPos & | fksolver, | ||
| TreeIkSolverVel & | iksolver, | ||
| unsigned int | maxiter = 100, | ||
| double | eps = 1e-6 ) |
Constructor of the solver, it needs the tree, a forward position kinematics solver and an inverse velocity kinematics solver for that tree, and a list of the segments you are interested in.
- Parameters
-
tree the tree to calculate the inverse position for endpoints the list of endpoints you are interested in. q_max the maximum joint positions q_min the minimum joint positions fksolver a forward position kinematics solver iksolver an inverse velocity kinematics solver maxiter the maximum Newton-Raphson iterations, default: 100 eps the precision for the position, used to end the iterations, default: epsilon (defined in kdl.hpp)
- Returns
◆ ~TreeIkSolverPos_NR_JL()
| KDL::TreeIkSolverPos_NR_JL::~TreeIkSolverPos_NR_JL | ( | ) |
Member Function Documentation
◆ CartToJnt()
|
virtual |
Calculate inverse position kinematics, from cartesian coordinates to joint coordinates.
- Parameters
-
q_init initial guess of the joint coordinates p_in input cartesian coordinates q_out output joint coordinates
- Returns
- if < 0 something went wrong otherwise (>=0) remaining (weighted) distance to target
Implements KDL::TreeIkSolverPos.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/treeiksolverpos_nr_jl.hpp
Generated by
 1.16.1