Recursive newton euler inverse dynamics solver for kinematic trees. More...
#include <treeidsolver_recursive_newton_euler.hpp>
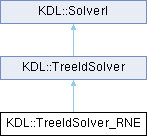
Public Member Functions | |
| TreeIdSolver_RNE (const Tree &tree, Vector grav) | |
| int | CartToJnt (const JntArray &q, const JntArray &q_dot, const JntArray &q_dotdot, const WrenchMap &f_ext, JntArray &torques) |
| virtual void | updateInternalDataStructures () |
| Public Member Functions inherited from KDL::SolverI | |
| SolverI () | |
| Initialize latest error to E_NOERROR. | |
| virtual | ~SolverI () |
| virtual int | getError () const |
| Return the latest error. | |
| virtual const char * | strError (const int error) const |
Additional Inherited Members | |
| Public Types inherited from KDL::SolverI | |
| enum | { E_DEGRADED = +1 , E_NOERROR = 0 , E_NO_CONVERGE = -1 , E_UNDEFINED = -2 , E_NOT_UP_TO_DATE = -3 , E_SIZE_MISMATCH = -4 , E_MAX_ITERATIONS_EXCEEDED = -5 , E_OUT_OF_RANGE = -6 , E_NOT_IMPLEMENTED = -7 , E_SVD_FAILED = -8 } |
| Protected Attributes inherited from KDL::SolverI | |
| int | error |
| Latest error, initialized to E_NOERROR in constructor. | |
Detailed Description
Recursive newton euler inverse dynamics solver for kinematic trees.
It calculates the torques for the joints, given the motion of the joints (q,qdot,qdotdot), external forces on the segments (expressed in the segments reference frame) and the dynamical parameters of the segments.
This is an extension of the inverse dynamic solver for kinematic chains,
- See also
- ChainIdSolver_RNE. The main difference is the use of STL maps instead of vectors to represent external wrenches (as well as internal variables exploited during the recursion).
Constructor & Destructor Documentation
◆ TreeIdSolver_RNE()
Constructor for the solver, it will allocate all the necessary memory
- Parameters
-
tree The kinematic tree to calculate the inverse dynamics for, an internal reference will be stored. grav The gravity vector to use during the calculation.
Member Function Documentation
◆ CartToJnt()
|
virtual |
Function to calculate from Cartesian forces to joint torques. Input parameters;
- Parameters
-
q The current joint positions q_dot The current joint velocities q_dotdot The current joint accelerations f_ext The external forces (no gravity) on the segments Output parameters: torques the resulting torques for the joints
Implements KDL::TreeIdSolver.
◆ updateInternalDataStructures()
|
virtual |
Update the internal data structures. This is required if the number of segments or number of joints of a chain/tree have changed. This provides a single point of contact for solver memory allocations.
Implements KDL::SolverI.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/treeidsolver_recursive_newton_euler.hpp
Generated by
 1.16.1