#include <trajectory_segment.hpp>
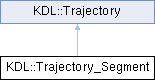
Trajectory_Segment combines a VelocityProfile and a Path into a trajectory
◆ Trajectory_Segment() [1/2]
| KDL::Trajectory_Segment::Trajectory_Segment |
( |
Path * | _geom, |
|
|
VelocityProfile * | _motprof, |
|
|
bool | _aggregate = true ) |
This constructor assumes that geom and <_motprof> are initialised correctly.
◆ Trajectory_Segment() [2/2]
| KDL::Trajectory_Segment::Trajectory_Segment |
( |
Path * | _geom, |
|
|
VelocityProfile * | _motprof, |
|
|
double | duration, |
|
|
bool | _aggregate = true ) |
This constructor assumes that geom is initialised and <_motprof> needs to be set according to duration.
◆ ~Trajectory_Segment()
| virtual KDL::Trajectory_Segment::~Trajectory_Segment |
( |
| ) |
|
|
virtual |
◆ Acc()
| virtual Twist KDL::Trajectory_Segment::Acc |
( |
double | time | ) |
const |
|
virtual |
◆ Clone()
| virtual Trajectory * KDL::Trajectory_Segment::Clone |
( |
| ) |
const |
|
inlinevirtual |
◆ Duration()
| virtual double KDL::Trajectory_Segment::Duration |
( |
| ) |
const |
|
virtual |
◆ GetPath()
| virtual Path * KDL::Trajectory_Segment::GetPath |
( |
| ) |
|
|
virtual |
◆ GetProfile()
◆ Pos()
| virtual Frame KDL::Trajectory_Segment::Pos |
( |
double | time | ) |
const |
|
virtual |
◆ Vel()
| virtual Twist KDL::Trajectory_Segment::Vel |
( |
double | time | ) |
const |
|
virtual |
◆ Write()
| virtual void KDL::Trajectory_Segment::Write |
( |
std::ostream & | os | ) |
const |
|
virtual |
The documentation for this class was generated from the following file:
 1.16.1