#include <path_composite.hpp>
Public Member Functions | |
| Path_Composite () | |
| void | Add (Path *geom, bool aggregate=true) |
| virtual double | LengthToS (double length) |
| virtual double | PathLength () |
| virtual Frame | Pos (double s) const |
| virtual Twist | Vel (double s, double sd) const |
| virtual Twist | Acc (double s, double sd, double sdd) const |
| virtual Path * | Clone () |
| virtual void | Write (std::ostream &os) |
| virtual int | GetNrOfSegments () |
| virtual Path * | GetSegment (int i) |
| virtual double | GetLengthToEndOfSegment (int i) |
| virtual void | GetCurrentSegmentLocation (double s, int &segment_number, double &inner_s) |
| virtual IdentifierType | getIdentifier () const |
| virtual | ~Path_Composite () |
| Public Member Functions inherited from KDL::Path | |
| virtual | ~Path () |
Additional Inherited Members | |
| Public Types inherited from KDL::Path | |
| enum | IdentifierType { ID_LINE =1 , ID_CIRCLE =2 , ID_COMPOSITE =3 , ID_ROUNDED_COMPOSITE =4 , ID_POINT =5 , ID_CYCLIC_CLOSED =6 } |
| Static Public Member Functions inherited from KDL::Path | |
| static Path * | Read (std::istream &is) |
Detailed Description
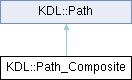
A Path being the composition of other Path objects.
For several of its methods, this class needs to lookup the segment corresponding to a value of the path variable s. To increase efficiency, this value is cached.
\TODO Currently a linear search is used to look up the segment. A binary search is more efficient. Can STL be used for this ? \TODO Increase the efficiency for caching for the common case of a fine grained monotonously increasing path variable s.
\TODO For all Path.., VelocityProfile.., Trajectory... check the bounds on the inputs with asserts.
\TODO explain this routine in the wiki.
Constructor & Destructor Documentation
◆ Path_Composite()
| KDL::Path_Composite::Path_Composite | ( | ) |
◆ ~Path_Composite()
|
virtual |
Member Function Documentation
◆ Acc()
|
virtual |
Returns the acceleration twist at path length s and with derivative of s == sd, and 2nd derivative of s == sdd
Implements KDL::Path.
◆ Add()
| void KDL::Path_Composite::Add | ( | Path * | geom, |
| bool | aggregate = true ) |
Adds a Path* to this composite
◆ Clone()
|
virtual |
◆ GetCurrentSegmentLocation()
|
virtual |
- Parameters
-
s [INPUT] path length variable for the composite. segment_number [OUTPUT] segments that corresponds to the path length variable s. inner_s [OUTPUT] path length to use within the segment.
◆ getIdentifier()
|
inlinevirtual |
◆ GetLengthToEndOfSegment()
|
virtual |
gets the length to the end of the given segment.
- Parameters
-
i segment number
- Returns
- length to the end of the segment, i.e. the value for s corresponding to the end of this segment.
◆ GetNrOfSegments()
|
virtual |
returns the number of underlying segments.
◆ GetSegment()
|
virtual |
◆ LengthToS()
|
virtual |
LengthToS() converts a physical length along the trajectory to the parameter s used in Pos, Vel and Acc. This is used because in cases with large rotations the parameter s does NOT correspond to the lineair length along the trajectory. User should be sure that the lineair distance travelled by this path object is NOT zero, when using this method ! (e.g. the case of only rotational change) throws Error_MotionPlanning_Not_Applicable if used on composed path objects.
Implements KDL::Path.
◆ PathLength()
|
virtual |
Returns the total path length of the trajectory (has dimension LENGTH) This is not always a physical length , ie when dealing with rotations that are dominant.
Implements KDL::Path.
◆ Pos()
|
virtual |
◆ Vel()
|
virtual |
Returns the velocity twist at path length s theta and with derivative of s == sd
Implements KDL::Path.
◆ Write()
|
virtual |
Writes one of the derived objects to the stream
Implements KDL::Path.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/path_composite.hpp
Generated by
 1.16.1