Solver for the inverse position kinematics that uses Levenberg-Marquardt. More...
#include <chainiksolverpos_lma.hpp>
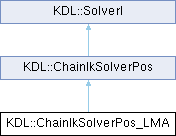
Public Member Functions | |
| ChainIkSolverPos_LMA (const KDL::Chain &_chain, const Eigen::Matrix< double, 6, 1 > &_l, double _eps=1E-5, int _maxiter=500, double _eps_joints=1E-15) | |
| constructs an ChainIkSolverPos_LMA solver. | |
| ChainIkSolverPos_LMA (const KDL::Chain &_chain, double _eps=1E-5, int _maxiter=500, double _eps_joints=1E-15) | |
| identical the full constructor for ChainIkSolverPos_LMA, but provides for a default weight matrix. | |
| virtual int | CartToJnt (const KDL::JntArray &q_init, const KDL::Frame &T_base_goal, KDL::JntArray &q_out) |
| computes the inverse position kinematics. | |
| virtual | ~ChainIkSolverPos_LMA () |
| destructor. | |
| void | compute_fwdpos (const VectorXq &q) |
| for internal use only. | |
| void | compute_jacobian (const VectorXq &q) |
| for internal use only. Only exposed for test and diagnostic purposes. compute_fwdpos(q) should always have been called before. | |
| void | display_jac (const KDL::JntArray &jval) |
| for internal use only. Only exposed for test and diagnostic purposes. | |
| void | updateInternalDataStructures () |
| virtual const char * | strError (const int error) const |
| Public Member Functions inherited from KDL::ChainIkSolverPos | |
| virtual | ~ChainIkSolverPos () |
| Public Member Functions inherited from KDL::SolverI | |
| SolverI () | |
| Initialize latest error to E_NOERROR. | |
| virtual | ~SolverI () |
| virtual int | getError () const |
| Return the latest error. | |
Public Attributes | |
| int | lastNrOfIter |
| contains the last number of iterations for an execution of CartToJnt. | |
| double | lastDifference |
| contains the last value for \( E \) after an execution of CartToJnt. | |
| double | lastTransDiff |
| contains the last value for the (unweighted) translational difference after an execution of CartToJnt. | |
| double | lastRotDiff |
| contains the last value for the (unweighted) rotational difference after an execution of CartToJnt. | |
| VectorXq | lastSV |
| contains the last values for the singular values of the weighted Jacobian after an execution of CartToJnt. | |
| MatrixXq | jac |
| for internal use only. | |
| VectorXq | grad |
| for internal use only. | |
| KDL::Frame | T_base_head |
| for internal use only. | |
| bool | display_information |
| display information on each iteration step to the console. | |
Static Public Attributes | |
| static const int | E_GRADIENT_JOINTS_TOO_SMALL = -100 |
| static const int | E_INCREMENT_JOINTS_TOO_SMALL = -101 |
Additional Inherited Members | |
| Public Types inherited from KDL::SolverI | |
| enum | { E_DEGRADED = +1 , E_NOERROR = 0 , E_NO_CONVERGE = -1 , E_UNDEFINED = -2 , E_NOT_UP_TO_DATE = -3 , E_SIZE_MISMATCH = -4 , E_MAX_ITERATIONS_EXCEEDED = -5 , E_OUT_OF_RANGE = -6 , E_NOT_IMPLEMENTED = -7 , E_SVD_FAILED = -8 } |
| Protected Attributes inherited from KDL::SolverI | |
| int | error |
| Latest error, initialized to E_NOERROR in constructor. | |
Detailed Description
Solver for the inverse position kinematics that uses Levenberg-Marquardt.
The robustness and speed of this solver is improved in several ways:
- by using a Levenberg-Marquardt method that automatically adapts the damping when computing the inverse damped least squares inverse velocity kinematics.
- by using an internal implementation of forward position kinematics and the Jacobian kinematics. This implementation is more numerically robust, is able to cache previous computations, and implements an \( \mathcal{O}(N) \) algorithm for the computation of the Jacobian (with \(N\), the number of joints, and for a fixed size task space).
- by providing a way to specify the weights in task space, you can weigh rotations wrt translations. This is important e.g. to specify that rotations do not matter for the problem at hand, or to specify how important you judge rotations w.r.t. translations, typically in S.I.-units, ([m],[rad]), the rotations are over-specified, this can be avoided using the weight matrix. Weights also make the solver more robust .
- only the constructors call memory allocation.
De general principles behind the optimisation is inspired on: Jorge Nocedal, Stephen J. Wright, Numerical Optimization,Springer-Verlag New York, 1999.
Constructor & Destructor Documentation
◆ ChainIkSolverPos_LMA() [1/2]
| KDL::ChainIkSolverPos_LMA::ChainIkSolverPos_LMA | ( | const KDL::Chain & | _chain, |
| const Eigen::Matrix< double, 6, 1 > & | _l, | ||
| double | _eps = 1E-5, | ||
| int | _maxiter = 500, | ||
| double | _eps_joints = 1E-15 ) |
constructs an ChainIkSolverPos_LMA solver.
The default parameters are chosen to be applicable to industrial-size robots (e.g. 0.5 to 3 meters range in task space), with an accuracy that is more then sufficient for typical industrial applications.
Weights are applied in task space, i.e. the kinematic solver minimizes: \( E = \Delta \mathbf{x}^T \mathbf{L} \mathbf{L}^T \Delta \mathbf{x} \), with \(\mathbf{L}\) a diagonal matrix.
- Parameters
-
_chain specifies the kinematic chain. _l specifies the "square root" of the weight (diagonal) matrix in task space. This diagonal matrix is specified as a vector. _eps specifies the desired accuracy in task space; after weighing with the weight matrix, it is applied on \(E\). _maxiter specifies the maximum number of iterations. _eps_joints specifies that the algorithm has to stop when the computed joint angle increments are smaller then _eps_joints. This is to avoid unnecessary computations up to _maxiter when the joint angle increments are so small that they effectively (in floating point) do not change the joint angles any more. The default is a few digits above numerical accuracy.
◆ ChainIkSolverPos_LMA() [2/2]
| KDL::ChainIkSolverPos_LMA::ChainIkSolverPos_LMA | ( | const KDL::Chain & | _chain, |
| double | _eps = 1E-5, | ||
| int | _maxiter = 500, | ||
| double | _eps_joints = 1E-15 ) |
identical the full constructor for ChainIkSolverPos_LMA, but provides for a default weight matrix.
\(\mathbf{L} = \mathrm{diag}\left( \begin{bmatrix} 1 & 1 & 1 & 0.01 & 0.01 & 0.01 \end{bmatrix} \right) \).
◆ ~ChainIkSolverPos_LMA()
|
virtual |
destructor.
Member Function Documentation
◆ CartToJnt()
|
virtual |
computes the inverse position kinematics.
- Parameters
-
q_init initial joint position. T_base_goal goal position expressed with respect to the robot base. q_out joint position that achieves the specified goal position (if successful).
- Returns
- E_NOERROR if successful, E_GRADIENT_JOINTS_TOO_SMALL the gradient of \( E \) towards the joints is to small, E_INCREMENT_JOINTS_TOO_SMALL if joint position increments are to small, E_MAX_ITER_EXCEEDED if number of iterations is exceeded.
Implements KDL::ChainIkSolverPos.
◆ compute_fwdpos()
| void KDL::ChainIkSolverPos_LMA::compute_fwdpos | ( | const VectorXq & | q | ) |
for internal use only.
Only exposed for test and diagnostic purposes.
◆ compute_jacobian()
| void KDL::ChainIkSolverPos_LMA::compute_jacobian | ( | const VectorXq & | q | ) |
for internal use only. Only exposed for test and diagnostic purposes. compute_fwdpos(q) should always have been called before.
◆ display_jac()
| void KDL::ChainIkSolverPos_LMA::display_jac | ( | const KDL::JntArray & | jval | ) |
for internal use only. Only exposed for test and diagnostic purposes.
◆ strError()
|
virtual |
Return a description of the latest error
- Returns
- if error is known then a description of error, otherwise "UNKNOWN ERROR"
Reimplemented from KDL::SolverI.
◆ updateInternalDataStructures()
|
virtual |
Update the internal data structures. This is required if the number of segments or number of joints of a chain/tree have changed. This provides a single point of contact for solver memory allocations.
Implements KDL::ChainIkSolverPos.
Member Data Documentation
◆ display_information
| bool KDL::ChainIkSolverPos_LMA::display_information |
display information on each iteration step to the console.
◆ E_GRADIENT_JOINTS_TOO_SMALL
|
static |
◆ E_INCREMENT_JOINTS_TOO_SMALL
|
static |
◆ grad
| VectorXq KDL::ChainIkSolverPos_LMA::grad |
for internal use only.
contains the gradient of the error criterion after an execution of CartToJnt.
◆ jac
| MatrixXq KDL::ChainIkSolverPos_LMA::jac |
for internal use only.
contains the last value for the Jacobian after an execution of compute_jacobian.
◆ lastDifference
| double KDL::ChainIkSolverPos_LMA::lastDifference |
contains the last value for \( E \) after an execution of CartToJnt.
◆ lastNrOfIter
| int KDL::ChainIkSolverPos_LMA::lastNrOfIter |
contains the last number of iterations for an execution of CartToJnt.
◆ lastRotDiff
| double KDL::ChainIkSolverPos_LMA::lastRotDiff |
contains the last value for the (unweighted) rotational difference after an execution of CartToJnt.
◆ lastSV
| VectorXq KDL::ChainIkSolverPos_LMA::lastSV |
contains the last values for the singular values of the weighted Jacobian after an execution of CartToJnt.
◆ lastTransDiff
| double KDL::ChainIkSolverPos_LMA::lastTransDiff |
contains the last value for the (unweighted) translational difference after an execution of CartToJnt.
◆ T_base_head
| KDL::Frame KDL::ChainIkSolverPos_LMA::T_base_head |
for internal use only.
contains the last value for the position of the tip of the robot (head) with respect to the base, after an execution of compute_jacobian.
The documentation for this class was generated from the following file:
- build/orocos_kdl_install/include/kdl/chainiksolverpos_lma.hpp
Generated by
 1.16.1